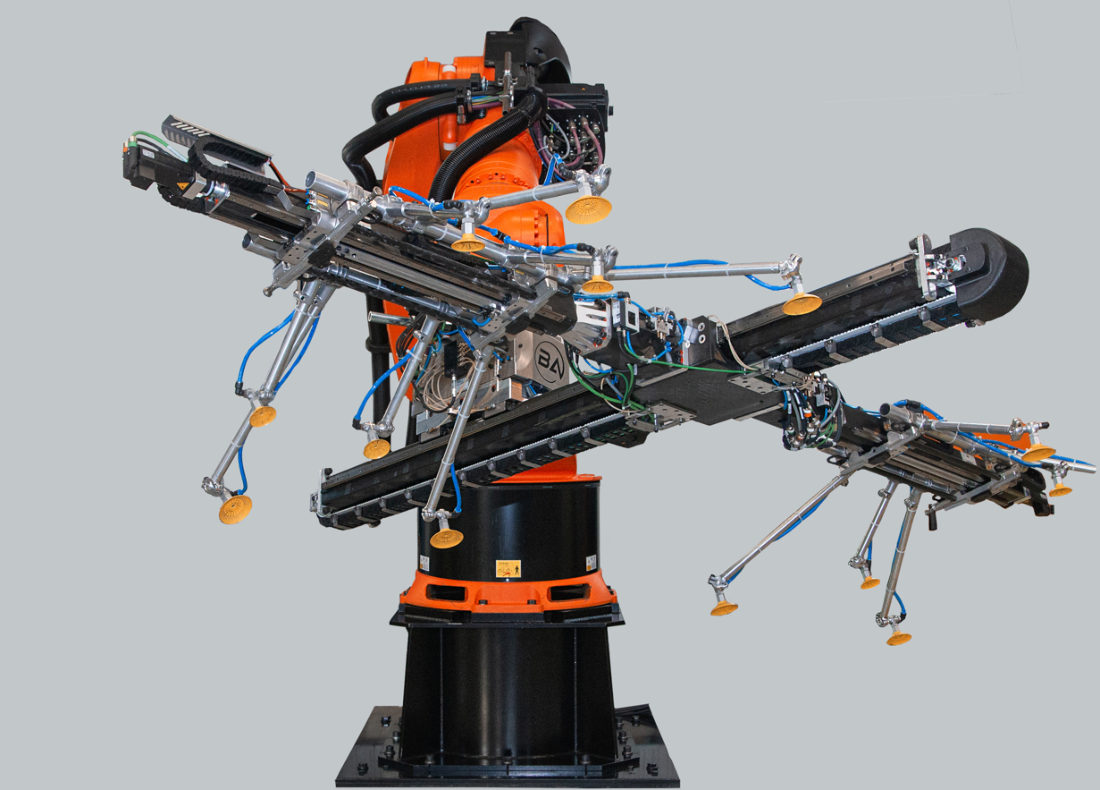
7th axis positioning and tool interchange
COBRA Crossbar
The crossbar that works as the robot's seventh axis — tilt, shift and transfer inside the robot's own motion profile.
What is COBRA
COBRA is a three-axis handling unit that mounts directly on the robot wrist and extends it into a dedicated press-to-press transfer robot. It adds axes 7, 8 and 9, fully synchronised with the robot's own controller — so the crossbar is planned as part of the kinematics rather than bolted on as a passive tool.
Axis 7 carries most of the transfer motion and enlarges the robot's reach; axes 8 and 9 reorient and reposition the gripper independently. A single robot moves parts cleanly from one press to the next while holding their orientation the whole way down the line.
Three axes, three jobs
- Integrated into the robot's controller; no external motion controller required
- Carbon-fibre B7 and B89 beams keep the structure light and stiff under load
- Robot adapter plate interfaces directly with the KUKA wrist
- Weight-optimised for dynamic cycles, cycle after cycle
- Modular design supports custom tooling interfaces
The difference
Traditional tool changers bolt the gripper to a fixed wrist interface. COBRA integrates positioning into the arm itself. The result: faster cycle times, fewer dedicated fixtures, and the flexibility to handle component variations in a single setup. One robot becomes many.
COBRA is engineered for press-room and stamping-line environments where component geometry, stack height and tooling variety demand adaptability without compromise. The same system suits a greenfield servo line and a press line that has been running for twenty years — in a retrofit it replaces ageing robots or mechanical feeders and hands the line back with a higher stroke rate than it ever achieved.
Linear
An omega-belt-driven carbon B7 beam telescopes up to 3,500 mm, powering transfer between presses spaced up to 8,000 mm apart.
Tilt
A planetary-gearbox drive tilts the tooling ±15° about the B8 axis, independent of linear and shift motion.
Shift
A ball-screw drive shifts the frame carriage ±150 mm sideways, fine-positioning the part without touching the other axes.
| Transfer distance (press spacing) | 8,000 mm |
|---|---|
| Telescopic travel (B7 axis) | 3,500 mm |
| Tilt (B8 axis) | ±15° |
| Shift (B9 axis) | ±150 mm |
| Total weight (on robot axis 6) | 280 kg |
Image gallery